Recent News
September 18 seminar: Daniel Seita
September 16, 2026
September 11 seminar: Viktoriia Babicheva
September 10, 2026
August 28 seminar: Behnam Roshanzadeh
August 27, 2026
August 21 seminar: Matthew Reno
August 19, 2026
News Archives
September 18 seminar: Daniel Seita
September 16, 2026
Fall 2026 ECE 590 Graduate Seminars
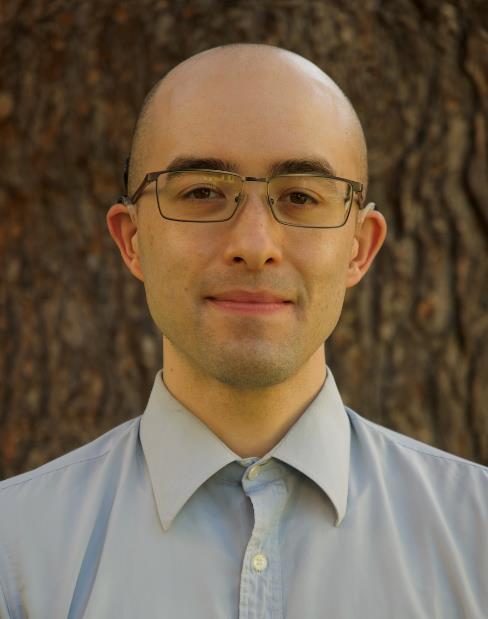
September 18, 2026
Doing More With Less: Expanding Experience and Preserving Capabilities in Robot Learning
Daniel Seita, University of Southern California
3:00 pm, UNM Centennial Engineering Center, Room 1026
Online Guests: Contact bidram@unm.edu for a Zoom link
Abstract: Robot learning has made impressive progress, but physical interaction remains expensive, and robots have finite physical resources This talk asks how robots can do more with less along two complementary dimensions First, how can we expand a robot’s experience from limited real world data? I will present methods that augment bimanual demonstrations across camera views, use video diffusion models to generate consistent visual variations and transfer data across robot embodiments, and extend augmentation to language, failure driven environment generation, and tactile signals Second, how can robots preserve capabilities during long horizon tasks? I will discuss dexterous manipulation methods that reuse object centric skills, coordinate sequential and concurrent actions, and allocate fingers so early actions do not consume resources needed later Together, these projects support generalist robots that can learn and compose diverse manipulation skills by expanding experience while preserving physical capabilities
Bio: Daniel Seita is an Assistant Professor in the Computer Science department at the University of Southern California and the director of the Sensing, Learning, and Understanding for Robotic Manipulation ( Lab His research interests are in computer vision, machine learning, and foundation models for robot manipulation, focusing on improving performance in visually and geometrically challenging settings Daniel was a postdoc at Carnegie Mellon University's Robotics Institute and holds a PhD in computer science from the University of California, Berkeley Daniel has been honored with the AAAI 2026 New Faculty Highlights program He presents his work at premier robotics conferences such as ICRA, IROS, RSS, and CoRL